My research focuses on multi-modal action composition — building generalizable robot behaviors by composing specialized models across sensory modalities and time scales.
Multisensory Learning: Integrating vision, touch, audio, and language for fine-grained, contact-rich manipulation.
Action Composition: Composing specialized models — skills, action abstractions, and physics-inspired world models — across diverse data and time scales to generalize to complex tasks.
I'm always excited to explore new collaborations in robotics and machine learning! If you're interested, please drop me an email. I'd love to chat!
haonan_chen [at] seas (dot) harvard (dot) edu /
haonan [at] cs (dot) stanford (dot) edu
News
[2026/11] I was selected as an Outstanding Reviewer for CoRL 2026.
Learning to Be Different: Component Specialization for Compositional Diffusion Policies Alec Laprevotte,
Haonan Chen,
Xiaoshen Han,
Yilun Du 2026 Conference on Robot Learning, [Project][Paper][Code][BibTeX]@inproceedings{laprevotte2026learningdifferentcomponentspecialization,
title={Learning to Be Different: Component Specialization for Compositional Diffusion Policies},
author={Alec Laprevotte and Haonan Chen and Xiaoshen Han and Yilun Du},
booktitle={Conference on Robot Learning},
year={2026},
eprint={2610.27194},
archivePrefix={arXiv},
primaryClass={cs.RO},
url={https://arxiv.org/abs/2610.27194}
}
Dream What I Can: Sparse Visual Planning for Long-Horizon Robot Manipulation
Chongkai Gao,
Wenlong Huang,
Haonan Chen,
Lin Shao,
Yilun Du,
Jiajun Wu,
Ruohan Zhang,
Li Fei-Fei
2026 Preprint, [Project][Paper][Code][BibTeX]@misc{gao2026dreamcan,
title={Dream What I Can: Sparse Visual Planning for Long-Horizon Robot Manipulation},
author={Chongkai Gao and Wenlong Huang and Haonan Chen and Lin Shao and Yilun Du and Jiajun Wu and Ruohan Zhang and Li Fei-Fei},
year={2026},
eprint={2610.24981},
archivePrefix={arXiv},
primaryClass={cs.RO},
url={https://arxiv.org/abs/2610.24981}
}
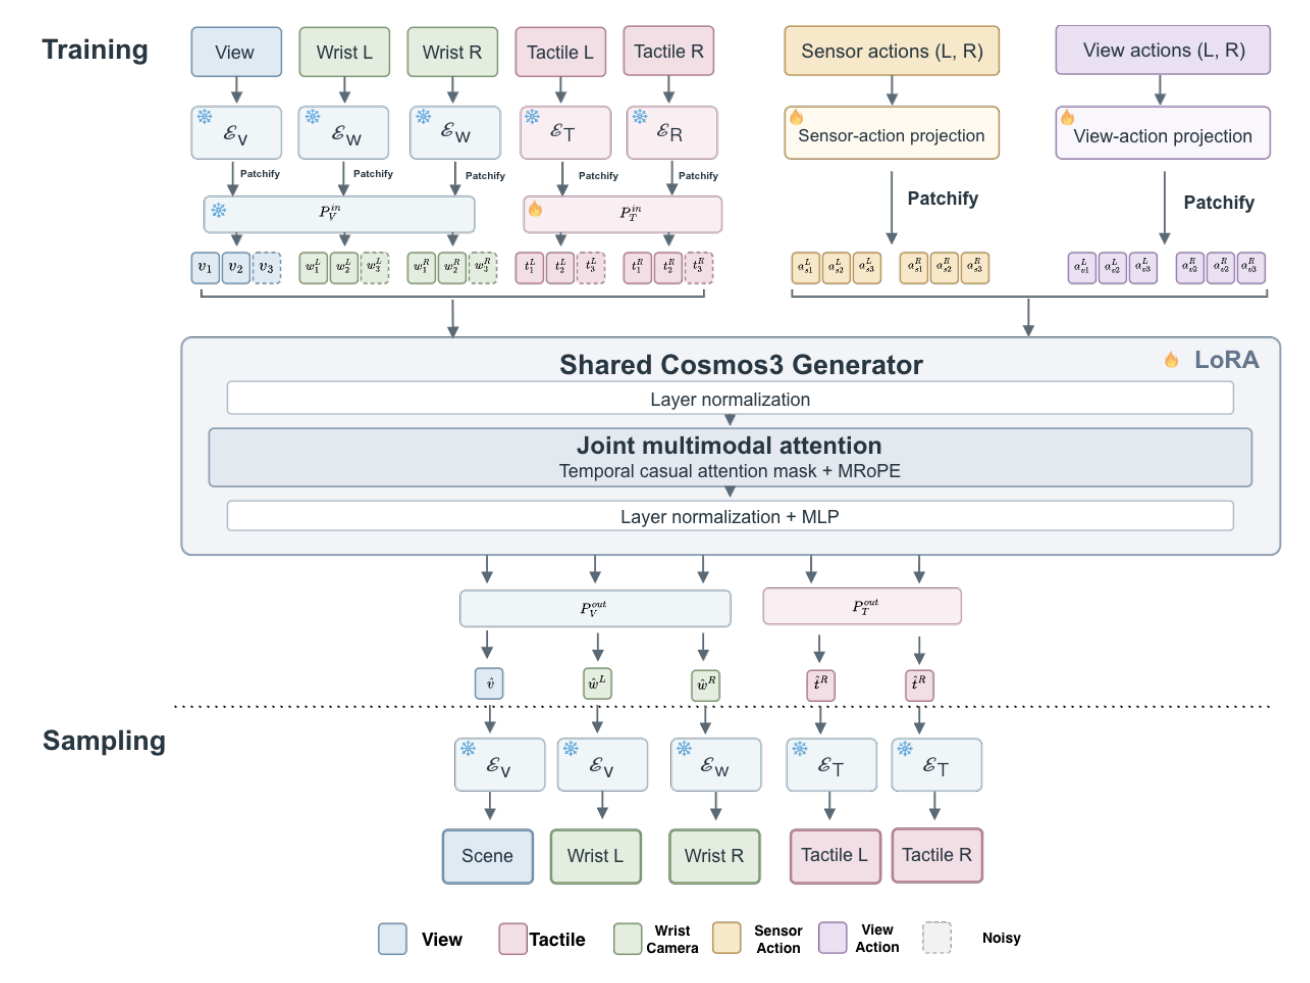
ACTS: Learning Visuo-Tactile World Models from Human Physical Interaction Yuxiang Ma,
Weihan Xu,
Pengfei Ye,
Anna Mei,
Yuxin Ray Song,
Tingle Li,
Haonan Chen,
Edward H. Adelson 2026 Preprint, [Project][Paper][BibTeX]@misc{ma2026acts,
title={ACTS: Learning Visuo-Tactile World Models from Human Physical Interaction},
author={Yuxiang Ma and Weihan Xu and Pengfei Ye and Anna Mei and Yuxin Ray Song and Tingle Li and Haonan Chen and Edward H. Adelson},
year={2026},
eprint={2610.24285},
archivePrefix={arXiv},
primaryClass={cs.RO},
url={https://arxiv.org/abs/2610.24285}
}
VisualForce: Robot Learning with Visual Predicted Force Haonan Chen*,
Feiyang Wu*,
Yuxiang Ma,
Mustafa Mete,
Pengfei Ye,
Junxuan Shen,
Cheng Zhu,
Aurora Ruggeri,
Kelvin Cheung,
Jiayuan Mao,
Edward Adelson,
Jiajun Wu,
Robert D. Howe,
Yilun Du * Equal contribution 2026 Preprint, [Project][Paper][Code][BibTeX]@misc{chen2026robotlearningvisualpredicted,
title={Robot Learning with Visual Predicted Force},
author={Haonan Chen and Feiyang Wu and Yuxiang Ma and Mustafa Mete and Pengfei Ye and Junxuan Shen and Cheng Zhu and Aurora Ruggeri and Kelvin Cheung and Jiayuan Mao and Edward Adelson and Jiajun Wu and Robert D. Howe and Yilun Du},
year={2026},
eprint={2610.04741},
archivePrefix={arXiv},
primaryClass={cs.RO},
url={https://arxiv.org/abs/2610.04741}
}
GlowTact: Simple and Compact Vision-Based Tactile Sensing with High Sensitivity and Spatial Resolution
Yuxiang Ma*,
Megha Tippur*,
Pengfei Ye,
Sandra Q. Liu,
Haonan Chen,
Francis Richard Cottrell,
Edward Adelson Humanoids 2026, [Project][Paper][BibTeX]@inproceedings{ma2026glowtact,
title={{GlowTact: Simple and Compact Vision-Based Tactile Sensing with High Sensitivity and Spatial Resolution}},
author={Ma, Yuxiang and Tippur, Megha and Ye, Pengfei and Liu, Sandra Q. and Chen, Haonan and Cottrell, Francis Richard and Adelson, Edward},
booktitle={2026 IEEE-RAS International Conference on Humanoid Robots (Humanoids)},
year={2026},
note={Accepted},
url={https://arxiv.org/abs/2609.32471}
}
ARGUS: Aligning Robot Scene Geometry Under Shifting Views with Large 3D Vision Models Rishik Sathua,
Haonan Chen,
Katherine Driggs-Campbell 2026 Preprint, [Project][Paper][BibTeX]@misc{sathua2026argusaligningrobotscene,
title={ARGUS: Aligning Robot Scene Geometry Under Shifting Views with Large 3D Vision Models},
author={Rishik Sathua and Haonan Chen and Katherine Driggs-Campbell},
year={2026},
eprint={2608.05579},
archivePrefix={arXiv},
primaryClass={cs.RO},
url={https://arxiv.org/abs/2608.05579}
}
Masked Visual Actions for Unified World Modeling Hadi Alzayer,
Wenlong Huang,
Haonan Chen,
Christopher Luey,
Lvmin Zhang,
Maneesh Agrawala,
Gordon Wetzstein,
Li Fei-Fei,
Yilun Du,
Jiajun Wu,
Jia-Bin Huang NeurIPS 2026, [Project][Paper][Code][BibTeX]@inproceedings{maskedvisualactions2026,
title={{Masked Visual Actions for Unified World Modeling}},
author={Hadi Alzayer and Wenlong Huang and Haonan Chen and Christopher Luey and Lvmin Zhang and Maneesh Agrawala and Gordon Wetzstein and Li Fei-Fei and Yilun Du and Jiajun Wu and Jia-Bin Huang},
year={2026},
eprint={2607.19343},
archivePrefix={arXiv},
url={https://arxiv.org/abs/2607.19343},
booktitle={Advances in Neural Information Processing Systems}
}
DriftWorld: Fast World Modeling through Drifting Susie Lu,
Haonan Chen,
Weirui Ye,
Yilun Du 2026 Preprint, [Project][Paper][Code][BibTeX]@misc{driftworld2026,
title={DriftWorld: Fast World Modeling through Drifting},
author={Susie Lu and Haonan Chen and Weirui Ye and Yilun Du},
year={2026},
eprint={2607.15065},
archivePrefix={arXiv},
url={https://arxiv.org/abs/2607.15065}
}
B-spline Policy: Accelerating Manipulation Policies via B-spline Action Representations Xiaoshen Han*,
Haoyu Xiong*,
Haonan Chen,
Chaoqi Liu,
Antonio Torralba,
Yuke Zhu,
Yilun Du * Equal contribution 2026 Preprint, [Project][Paper][Code][BibTeX]@article{han2026b,
title={B-spline Policy: Accelerating Manipulation Policies via B-spline Action Representations},
author={Han, Xiaoshen and Xiong, Haoyu and Chen, Haonan and Liu, Chaoqi and Torralba, Antonio and Zhu, Yuke and Du, Yilun},
journal={arXiv preprint arXiv:2607.09648},
year={2026}
}
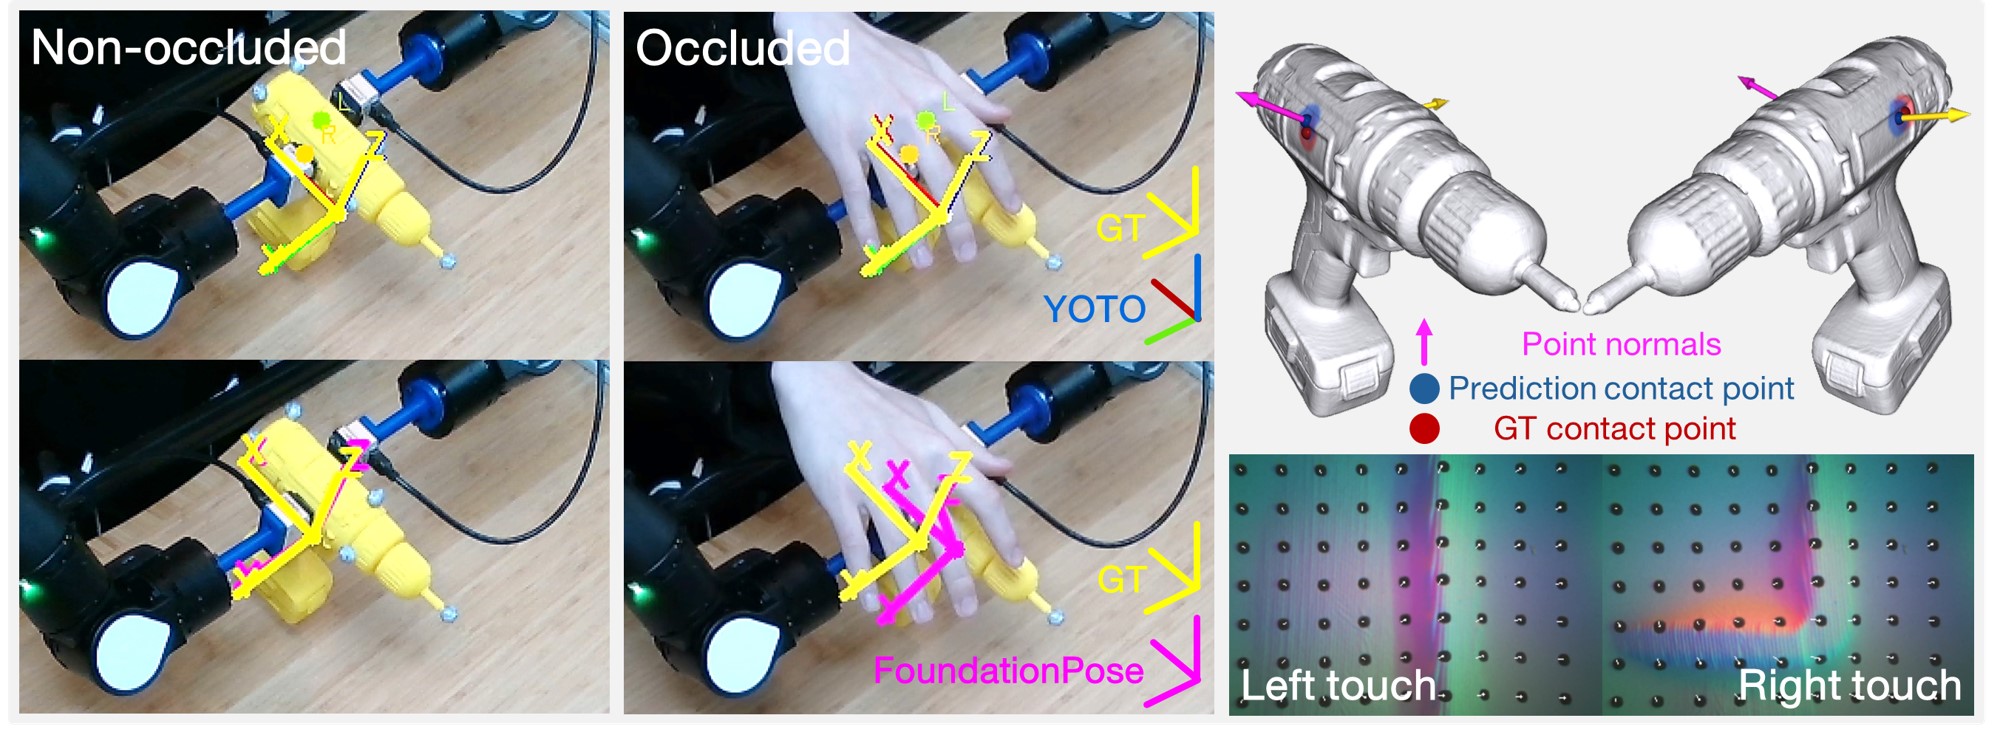
You Only Touch Once: 6-DoF Object Pose Estimation from Single Tactile Contact
Pengfei Ye,
Yuxiang Ma,
Haonan Chen,
Guangming Wang,
Yixiong Jing,
Brian Sheil,
Yilun Du,
Edward Adelson 2026 Preprint, [Paper][BibTeX]@misc{ye2026youonlytouchonce,
title={You Only Touch Once: 6-DoF Object Pose Estimation from Single Tactile Contact},
author={Pengfei Ye and Yuxiang Ma and Haonan Chen and Guangming Wang and Yixiong Jing and Brian Sheil and Yilun Du and Edward Adelson},
year={2026},
eprint={2606.28899},
archivePrefix={arXiv},
primaryClass={cs.RO},
url={https://arxiv.org/abs/2606.28899}
}
MemoBench: Benchmarking World Modeling in Dynamically Changing Environments Haoyu Chen,
Kaichen Zhou,
Hang Hua,
Kaile Zhang,
Jingwen Qian,
Wufei Ma,
Haonan Chen,
Chunjiang Liu,
Yizhou Zhao,
Xiaoyuan Wang,
Weiyue Li,
Alan Yuille,
Paul Pu Liang,
Yilun Du 2026 European Conference on Computer Vision, [Project][Paper][Code][BibTeX]@inproceedings{chen2026memobench,
title={MemoBench: Benchmarking World Modeling in Dynamically Changing Environments},
author={Haoyu Chen and Kaichen Zhou and Hang Hua and Kaile Zhang and Jingwen Qian and Wufei Ma and Haonan Chen and Chunjiang Liu and Yizhou Zhao and Xiaoyuan Wang and Weiyue Li and Alan Yuille and Paul Pu Liang and Yilun Du},
booktitle={European Conference on Computer Vision},
year={2026},
url={https://arxiv.org/abs/2606.27537}
}
CoStream: Composing Simple Behaviors for Generalizable Complex Manipulation
Haonan Chen*,
Yuxiang Ma*,
Stephen Tian,
Xiaoshen Han,
Wenlong Huang,
Feiyang Wu,
Yunzhu Li,
Jiajun Wu,
Edward H. Adelson,
Yilun Du * Equal contribution 2026 Conference on Robot Learning, [Project][Paper][BibTeX]@inproceedings{costream2026,
title={{CoStream: Composing Simple Behaviors for Generalizable Complex Manipulation}},
author={Chen, Haonan and Ma, Yuxiang and Tian, Stephen and Han, Xiaoshen and Huang, Wenlong and Wu, Feiyang and Li, Yunzhu and Wu, Jiajun and Adelson, Edward H. and Du, Yilun},
booktitle={Conference on Robot Learning},
year={2026},
url={https://arxiv.org/abs/2606.26423}
}
OAT: Ordered Action Tokenization
Chaoqi Liu,
Xiaoshen Han,
Jiawei Gao,
Yue Zhao,
Haonan Chen,
Yilun Du 2026 Robotics: Science and Systems, [Project][Paper][Code][Blog][BibTeX] Finalist - Best/Outstanding Paper Awards Media Coverage:[MarkTechPost]@inproceedings{liu2026orderedactiontokenization,
author={Chaoqi Liu AND Xiaoshen Han AND Jiawei Gao AND Yue Zhao AND Haonan Chen AND Yilun Du},
title={{OAT: Ordered Action Tokenization}},
booktitle={Proceedings of Robotics: Science and Systems},
year={2026},
address={Sydney, Australia},
month={July},
doi={10.15607/RSS.2026.XXII.075}
}
IMPACT: Learning Internal-Model Predictive Control for Forceful Robotic Manipulation
Jiawei Gao,
Chaoqi Liu,
Peilin Wu,
Haonan Chen,
Yilun Du 2026 Preprint, [Project][Paper][Code][Video][BibTeX]@misc{gao2026impact,
title={{IMPACT: Learning Internal-Model Predictive Control for Forceful Robotic Manipulation}},
author={Gao, Jiawei and Liu, Chaoqi and Wu, Peilin and Chen, Haonan and Du, Yilun},
year={2026},
eprint={2606.10818},
archivePrefix={arXiv},
primaryClass={cs.RO},
url={https://arxiv.org/abs/2606.10818}
}
SIMPACT: Simulation-Enabled Action Planning using Vision-Language Models
Haowen Liu*,
Shaoxiong Yao*,
Haonan Chen,
Jiawei Gao,
Jiayuan Mao,
Jia-Bin Huang,
Yilun Du * Equal contribution 2026 IEEE/CVF Conference on Computer Vision and Pattern Recognition, [Project][Paper][BibTeX]@inproceedings{liu2026cvpr,
author={Liu, Haowen and Yao, Shaoxiong and Chen, Haonan and Gao, Jiawei and Mao, Jiayuan and Huang, Jia-Bin and Du, Yilun},
title={{SIMPACT: Simulation-Enabled Action Planning using Vision-Language Models}},
booktitle={Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR)},
month={June},
year={2026},
pages={20790--20801}
}
Gotta Scoop ’Em All: Sim-and-Real Co-Training of Graph-based Neural Dynamics for Long-Horizon Scooping Kaiwen Hong,
Haonan Chen*,
Jiaming Xu*,
Runxuan Wang*,
Kaylan Wang,
Mingtong Zhang,
Shuijing Liu,
Yifan Zhu,
Yunzhu Li,
Katherine Driggs-Campbell * Equal contribution 2026 IEEE International Conference on Robotics and Automation, [Project][Paper][BibTeX]@inproceedings{hong2026gottascoop,
title={Gotta Scoop 'Em All: Sim-and-Real Co-Training of Graph-based Neural Dynamics for Long-Horizon Scooping},
author={Hong, Kaiwen and Chen, Haonan and Xu, Jiaming and Wang, Runxuan and Wang, Kaylan and Zhang, Mingtong and Liu, Shuijing and Zhu, Yifan and Li, Yunzhu and Driggs-Campbell, Katherine},
booktitle={2026 IEEE International Conference on Robotics and Automation (ICRA)},
year={2026},
url={https://jerrywrx.github.io/data/ICRA26_4643_FI.pdf}
}
Multi-Modal Manipulation via Multi-Modal Policy Consensus
Haonan Chen,
Jiaming Xu*,
Hongyu Chen*,
Kaiwen Hong,
Binghao Huang,
Chaoqi Liu,
Jiayuan Mao,
Yunzhu Li,
Yilun Du+,
Katherine Driggs-Campbell+ * Equal contribution; + Equal advising 2026 IEEE International Conference on Robotics and Automation, [Project][Paper][Code][Dataset][Video][Audio][Blog][Deepwiki][BibTeX]@inproceedings{chen2026multimodal,
title={{Multi-Modal Manipulation via Multi-Modal Policy Consensus}},
author={Chen, Haonan and Xu, Jiaming and Chen, Hongyu and Hong, Kaiwen and Huang, Binghao and Liu, Chaoqi and Mao, Jiayuan and Li, Yunzhu and Du, Yilun and Driggs-Campbell, Katherine},
booktitle={2026 IEEE International Conference on Robotics and Automation (ICRA)},
year={2026},
url={https://arxiv.org/abs/2509.23468}
} Best Paper Award at CVPR 2026 Workshop on Multi-Sensory Modeling for Embodied Intelligence [Link] Media Coverage: Featured in Video Friday on [IEEE Spectrum]
Flexible Multitask Learning with Factorized Diffusion Policy
Chaoqi Liu,
Haonan Chen,
Sigmund H. Høeg*,
Shaoxiong Yao*,
Yunzhu Li,
Kris Hauser,
Yilun Du * Equal contribution 2026 IEEE Robotics and Automation Letters, [Project][Paper][BibTeX]@article{liu2026flexible,
author={Liu, Chaoqi and Chen, Haonan and H{\o}eg, Sigmund H. and Yao, Shaoxiong and Li, Yunzhu and Hauser, Kris and Du, Yilun},
journal={IEEE Robotics and Automation Letters},
title={{Flexible Multitask Learning With Factorized Diffusion Policy}},
year={2026},
volume={11},
number={4},
pages={4697--4704},
doi={10.1109/LRA.2026.3664611}
}
Tool-as-Interface: Learning Robot Policies from Observing Human Tool Use
Haonan Chen,
Cheng Zhu,
Shuijing Liu,
Yunzhu Li,
Katherine Driggs-Campbell 2025 Conference on Robot Learning, [Project][Paper][Code][BibTeX]@inproceedings{chen2025tool,
title={{Tool-as-Interface: Learning Robot Policies from Observing Human Tool Use}},
author={Chen, Haonan and Zhu, Cheng and Liu, Shuijing and Li, Yunzhu and Driggs-Campbell, Katherine Rose},
booktitle={Proceedings of The 9th Conference on Robot Learning},
pages={2695--2713},
year={2025},
editor={Lim, Joseph and Song, Shuran and Park, Hae-Won},
volume={305},
series={Proceedings of Machine Learning Research},
month={27--30 Sep},
publisher={PMLR},
pdf={https://raw.githubusercontent.com/mlresearch/v305/main/assets/chen25d/chen25d.pdf},
url={https://proceedings.mlr.press/v305/chen25d.html}
} Best Paper Award at ICRA 2025 Workshop on Foundation Models and Neuro-Symbolic AI for Robotics [Link] Best Presentation Award at CSL Student Conference 2025[Link] Media Coverage: Featured in Video Friday on [IEEE Spectrum] Media Coverage:[The Grainger College of Engineering], [TechXplore], [Hackster.io]
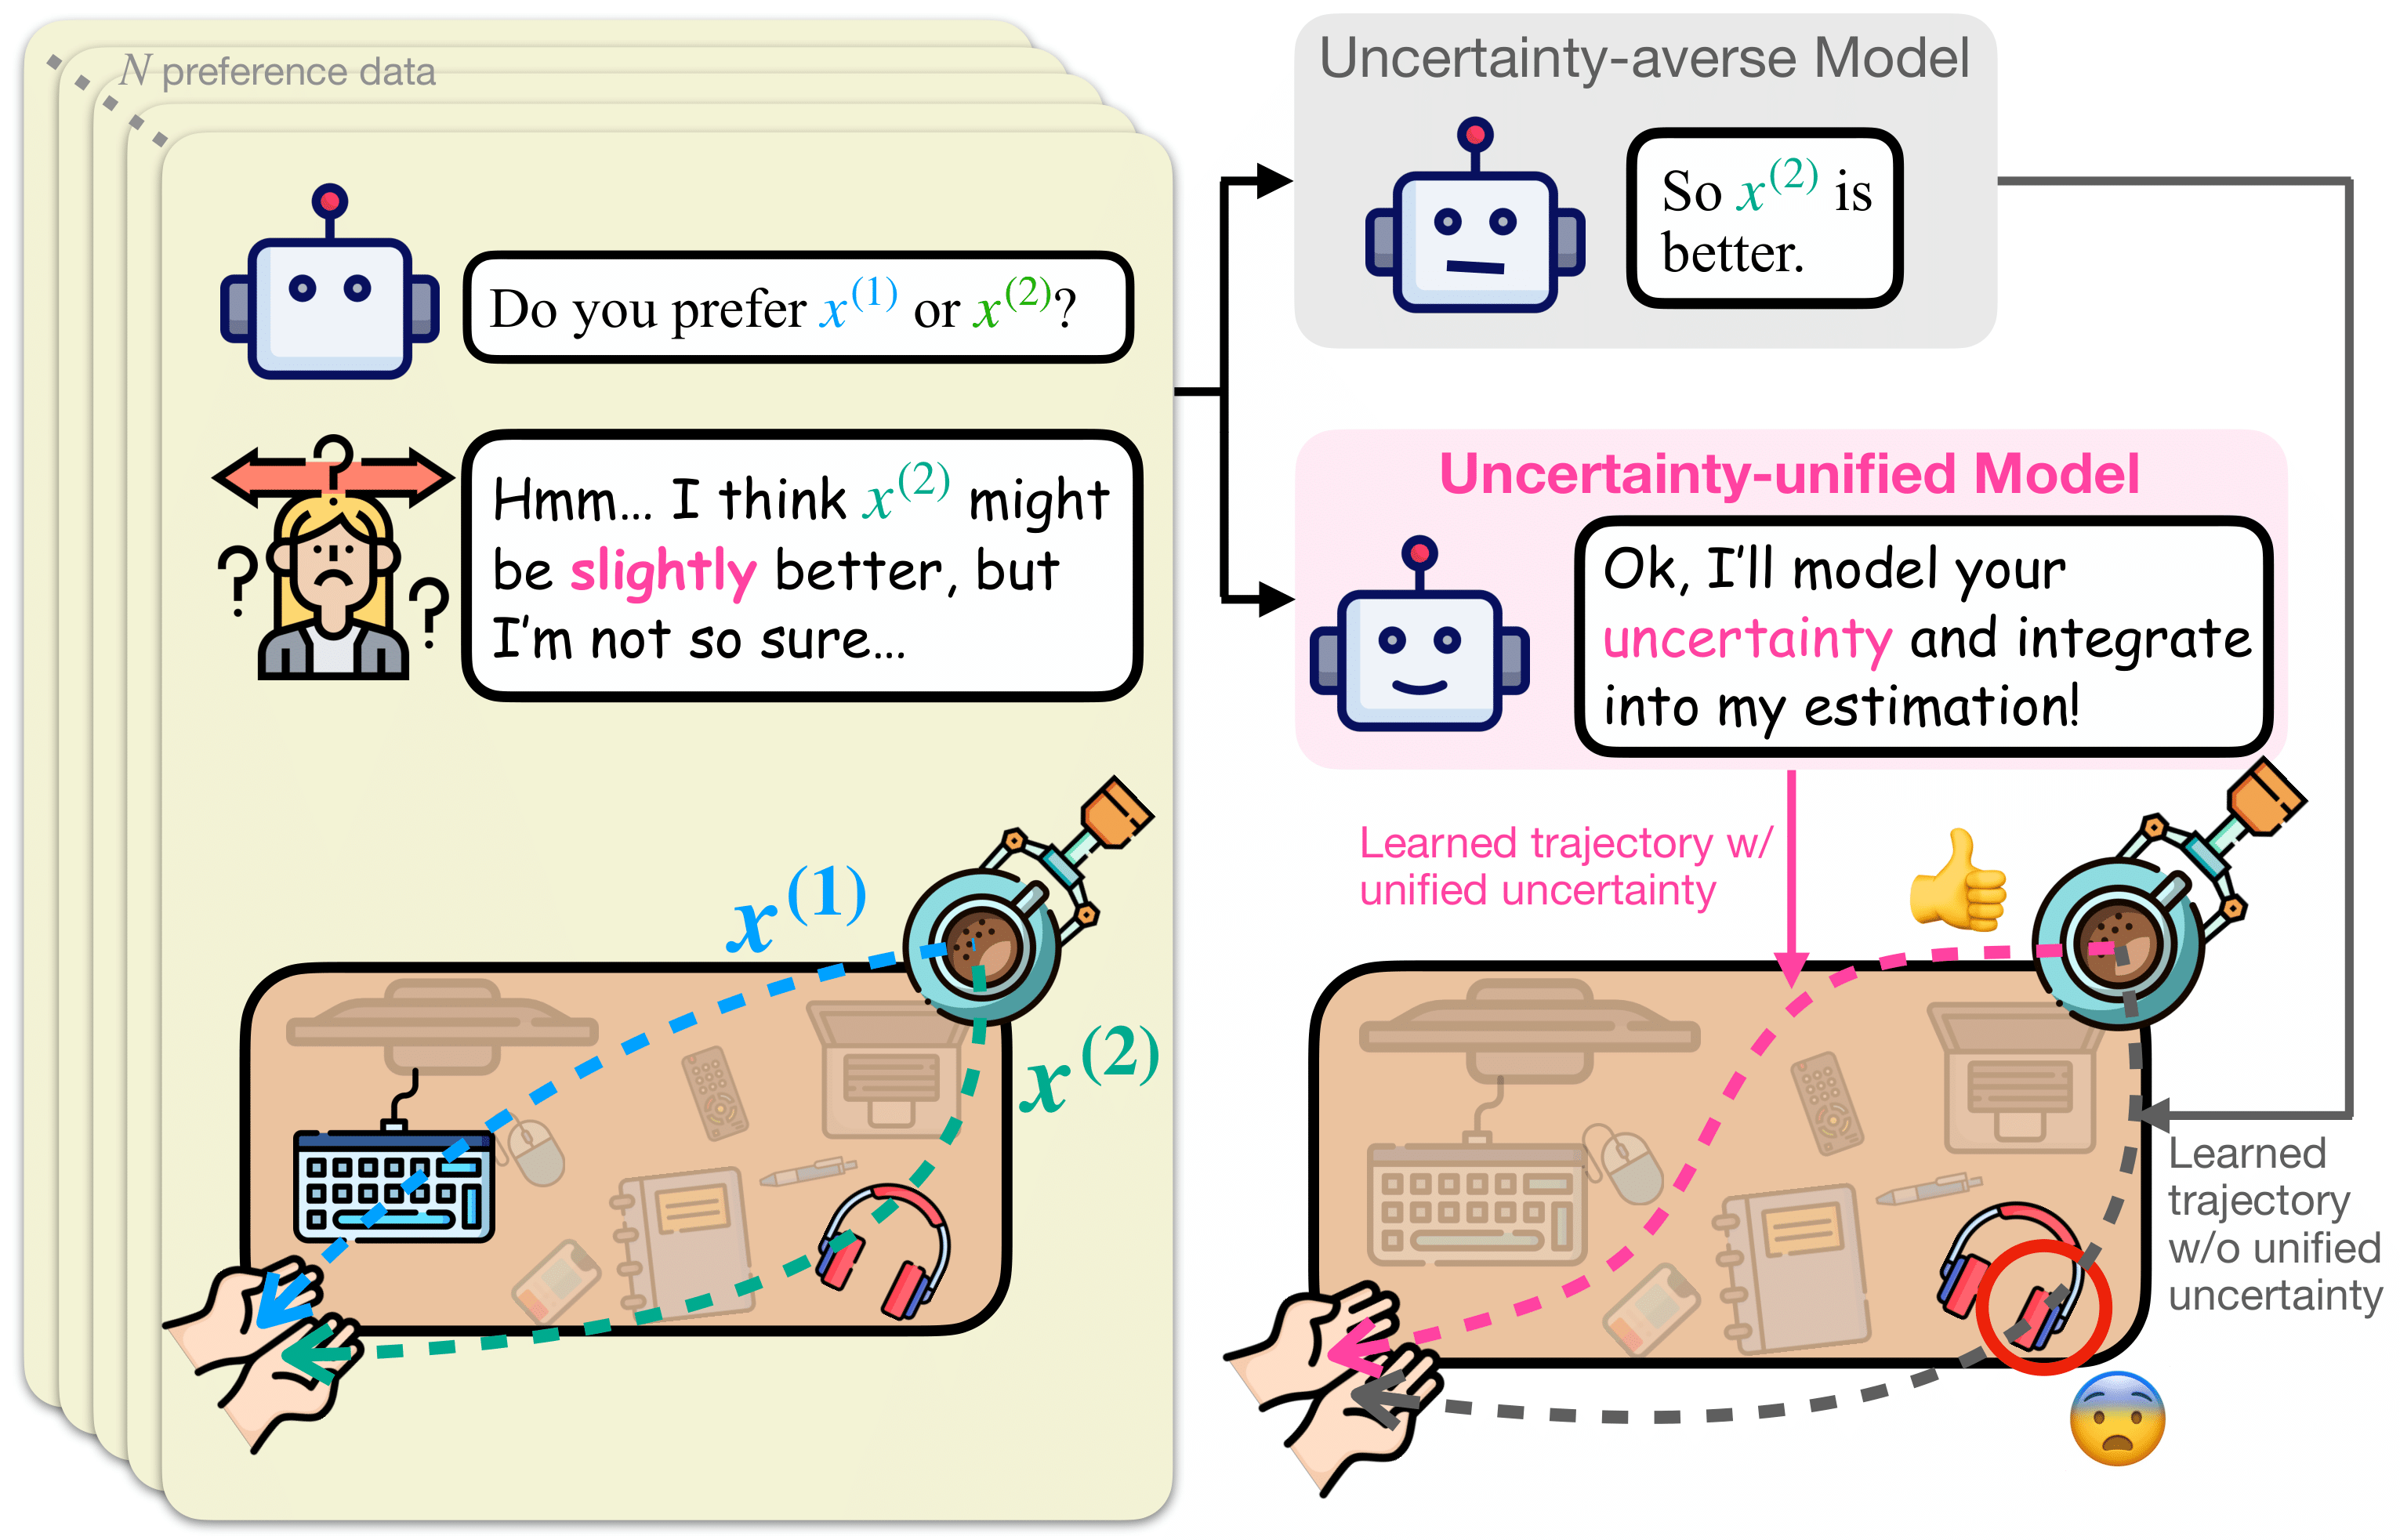
Towards Uncertainty Unification: A Case Study for Preference Learning
Shaoting Peng,
Haonan Chen,
Katherine Driggs-Campbell 2025 Robotics: Science and Systems, [Project][Paper][Code][Video][BibTeX]@inproceedings{peng2025towards,
author={Shaoting Peng AND Haonan Chen AND Katherine Rose Driggs-Campbell},
title={{Towards Uncertainty Unification: A Case Study for Preference Learning}},
booktitle={Proceedings of Robotics: Science and Systems},
year={2025},
address={LosAngeles, CA, USA},
month={June},
doi={10.15607/RSS.2025.XXI.091}
} Best Paper Award at ICRA 2026 Workshop on Uncertainty in Open-World Robotics
Learning Coordinated Bimanual Manipulation Policies using State Diffusion and Inverse Dynamics Models
Haonan Chen,
Jiaming Xu*,
Lily Sheng*,
Tianchen Ji,
Shuijing Liu,
Yunzhu Li,
Katherine Driggs-Campbell * Equal contribution 2025 IEEE International Conference on Robotics and Automation, [Project][Paper][BibTeX]@inproceedings{chen2025learning,
title={{Learning Coordinated Bimanual Manipulation Policies Using State Diffusion and Inverse Dynamics Models}},
author={Chen, Haonan and Xu, Jiaming and Sheng, Lily and Ji, Tianchen and Liu, Shuijing and Li, Yunzhu and Driggs-Campbell, Katherine},
booktitle={2025 IEEE International Conference on Robotics and Automation (ICRA)},
year={2025},
pages={5644--5651},
doi={10.1109/icra55743.2025.11127387},
url={https://doi.org/10.1109/icra55743.2025.11127387}
}
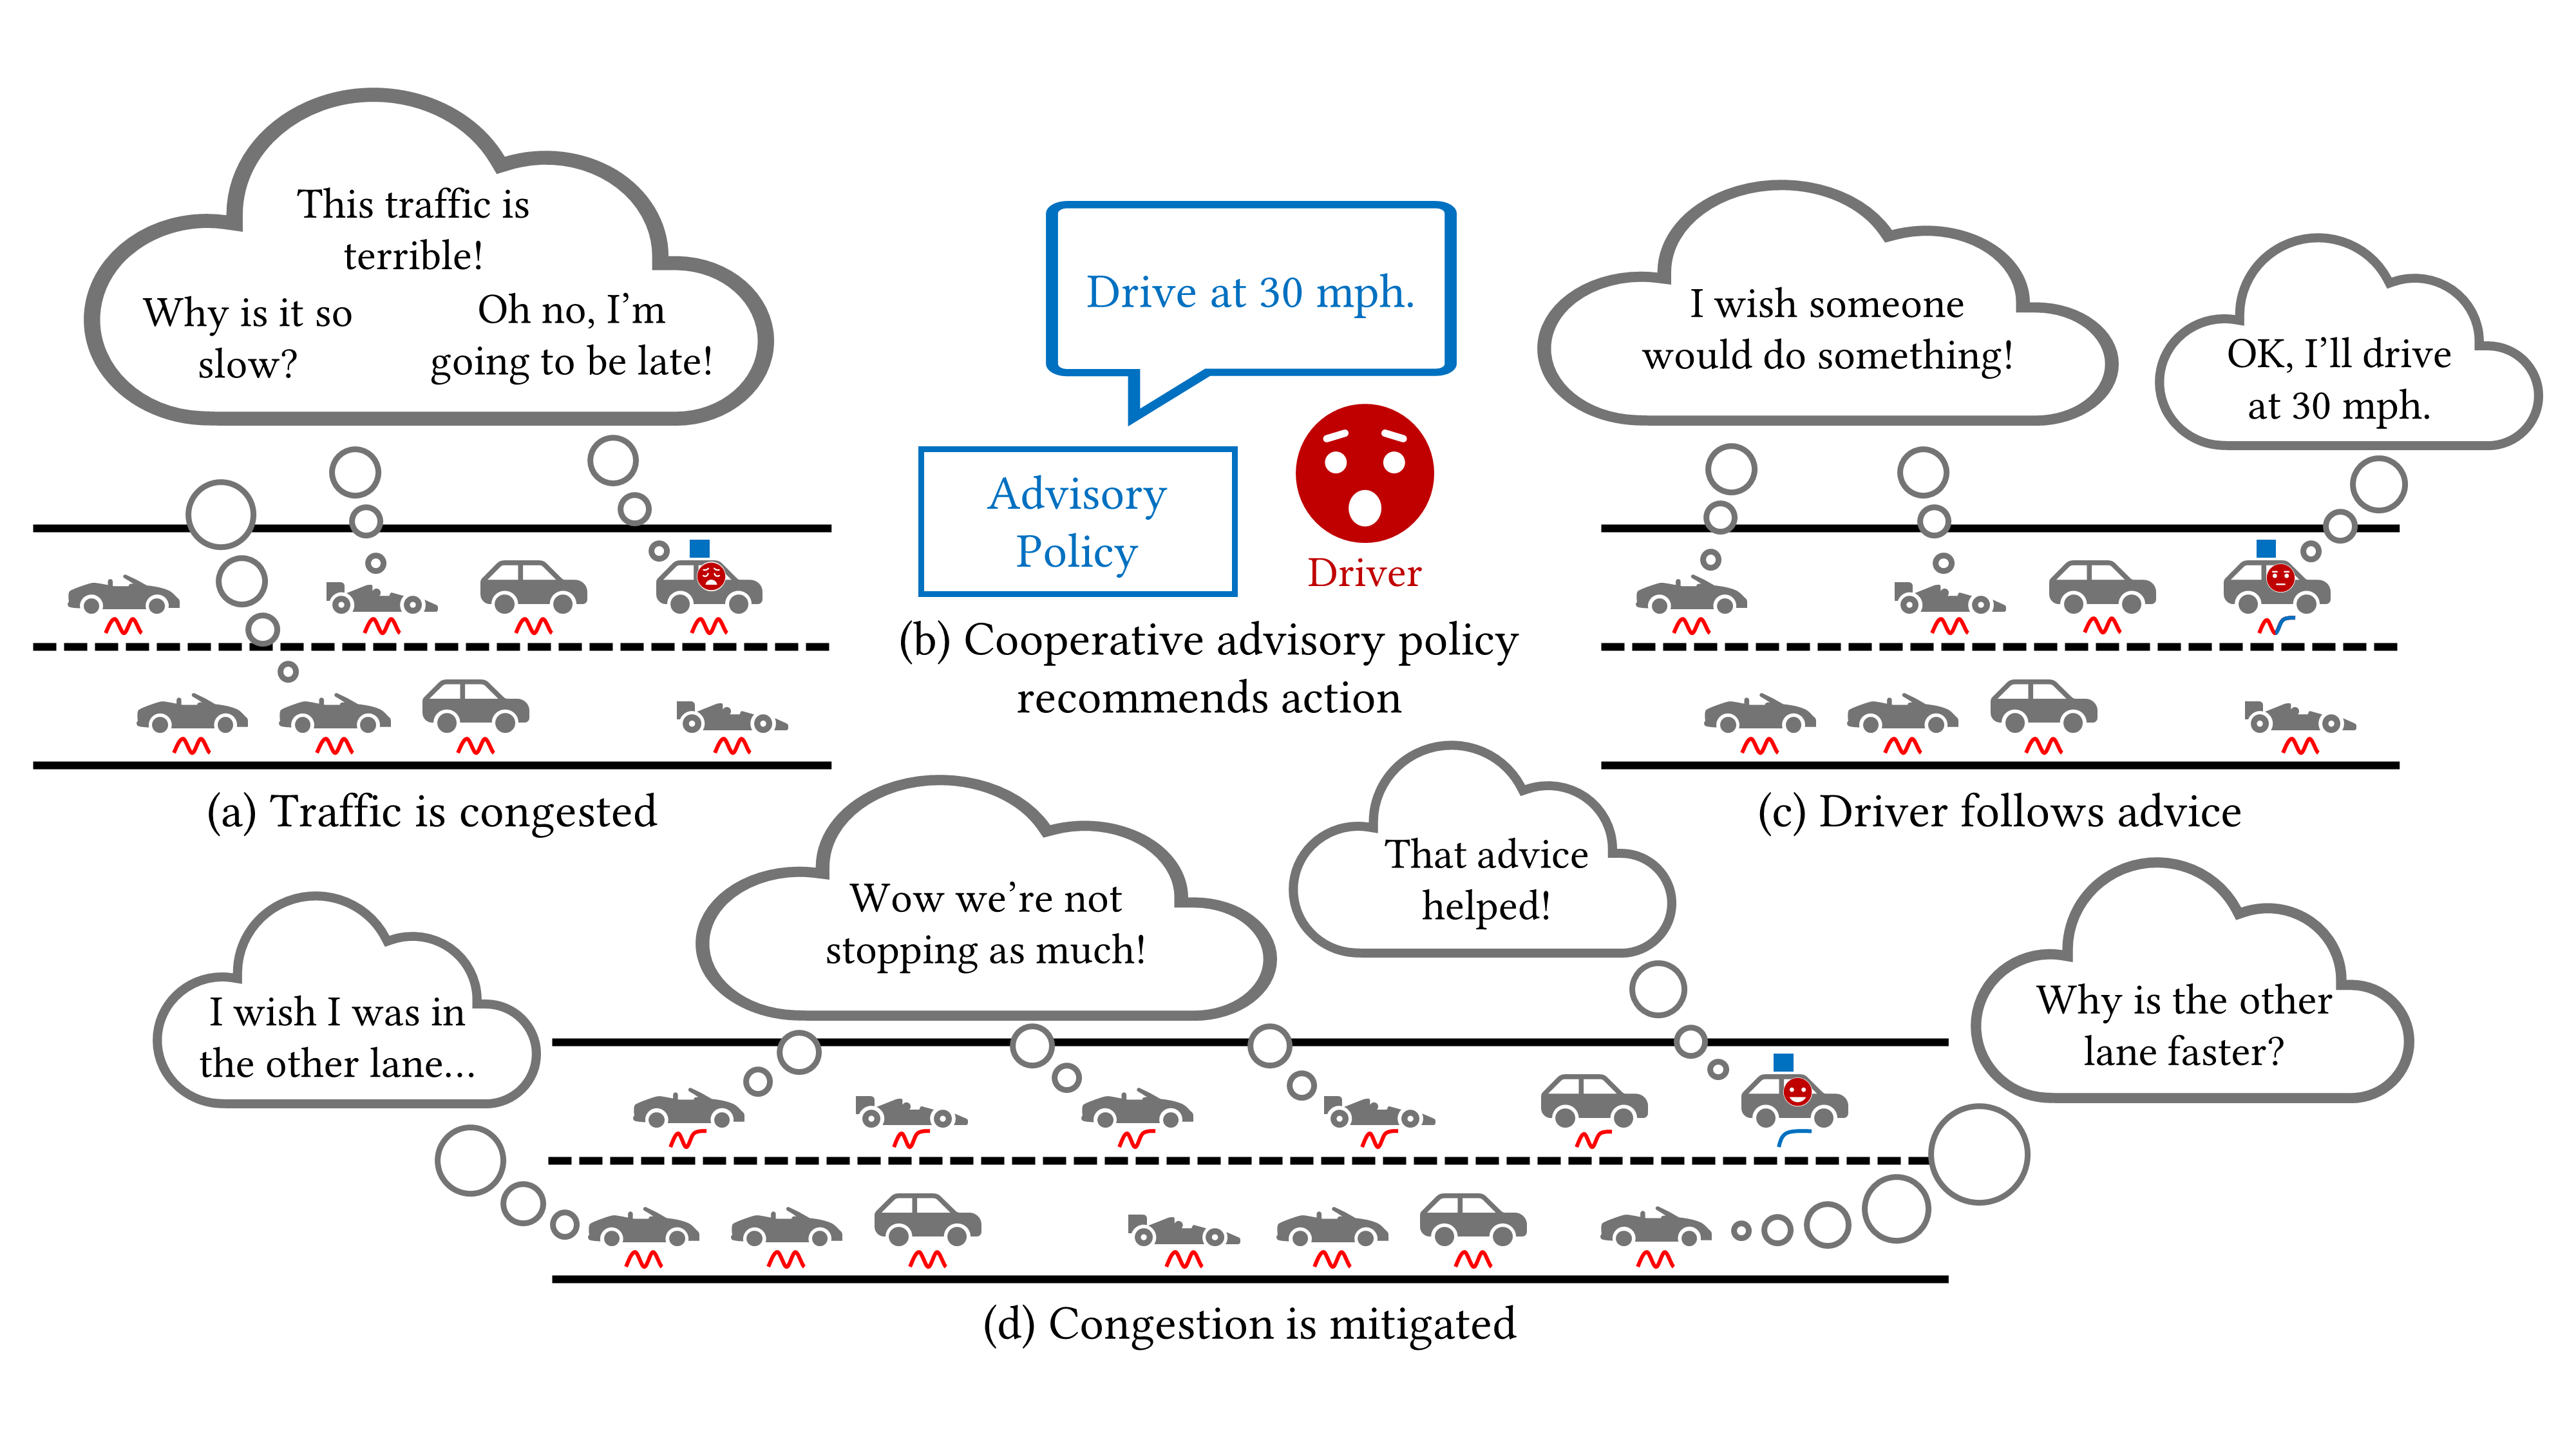
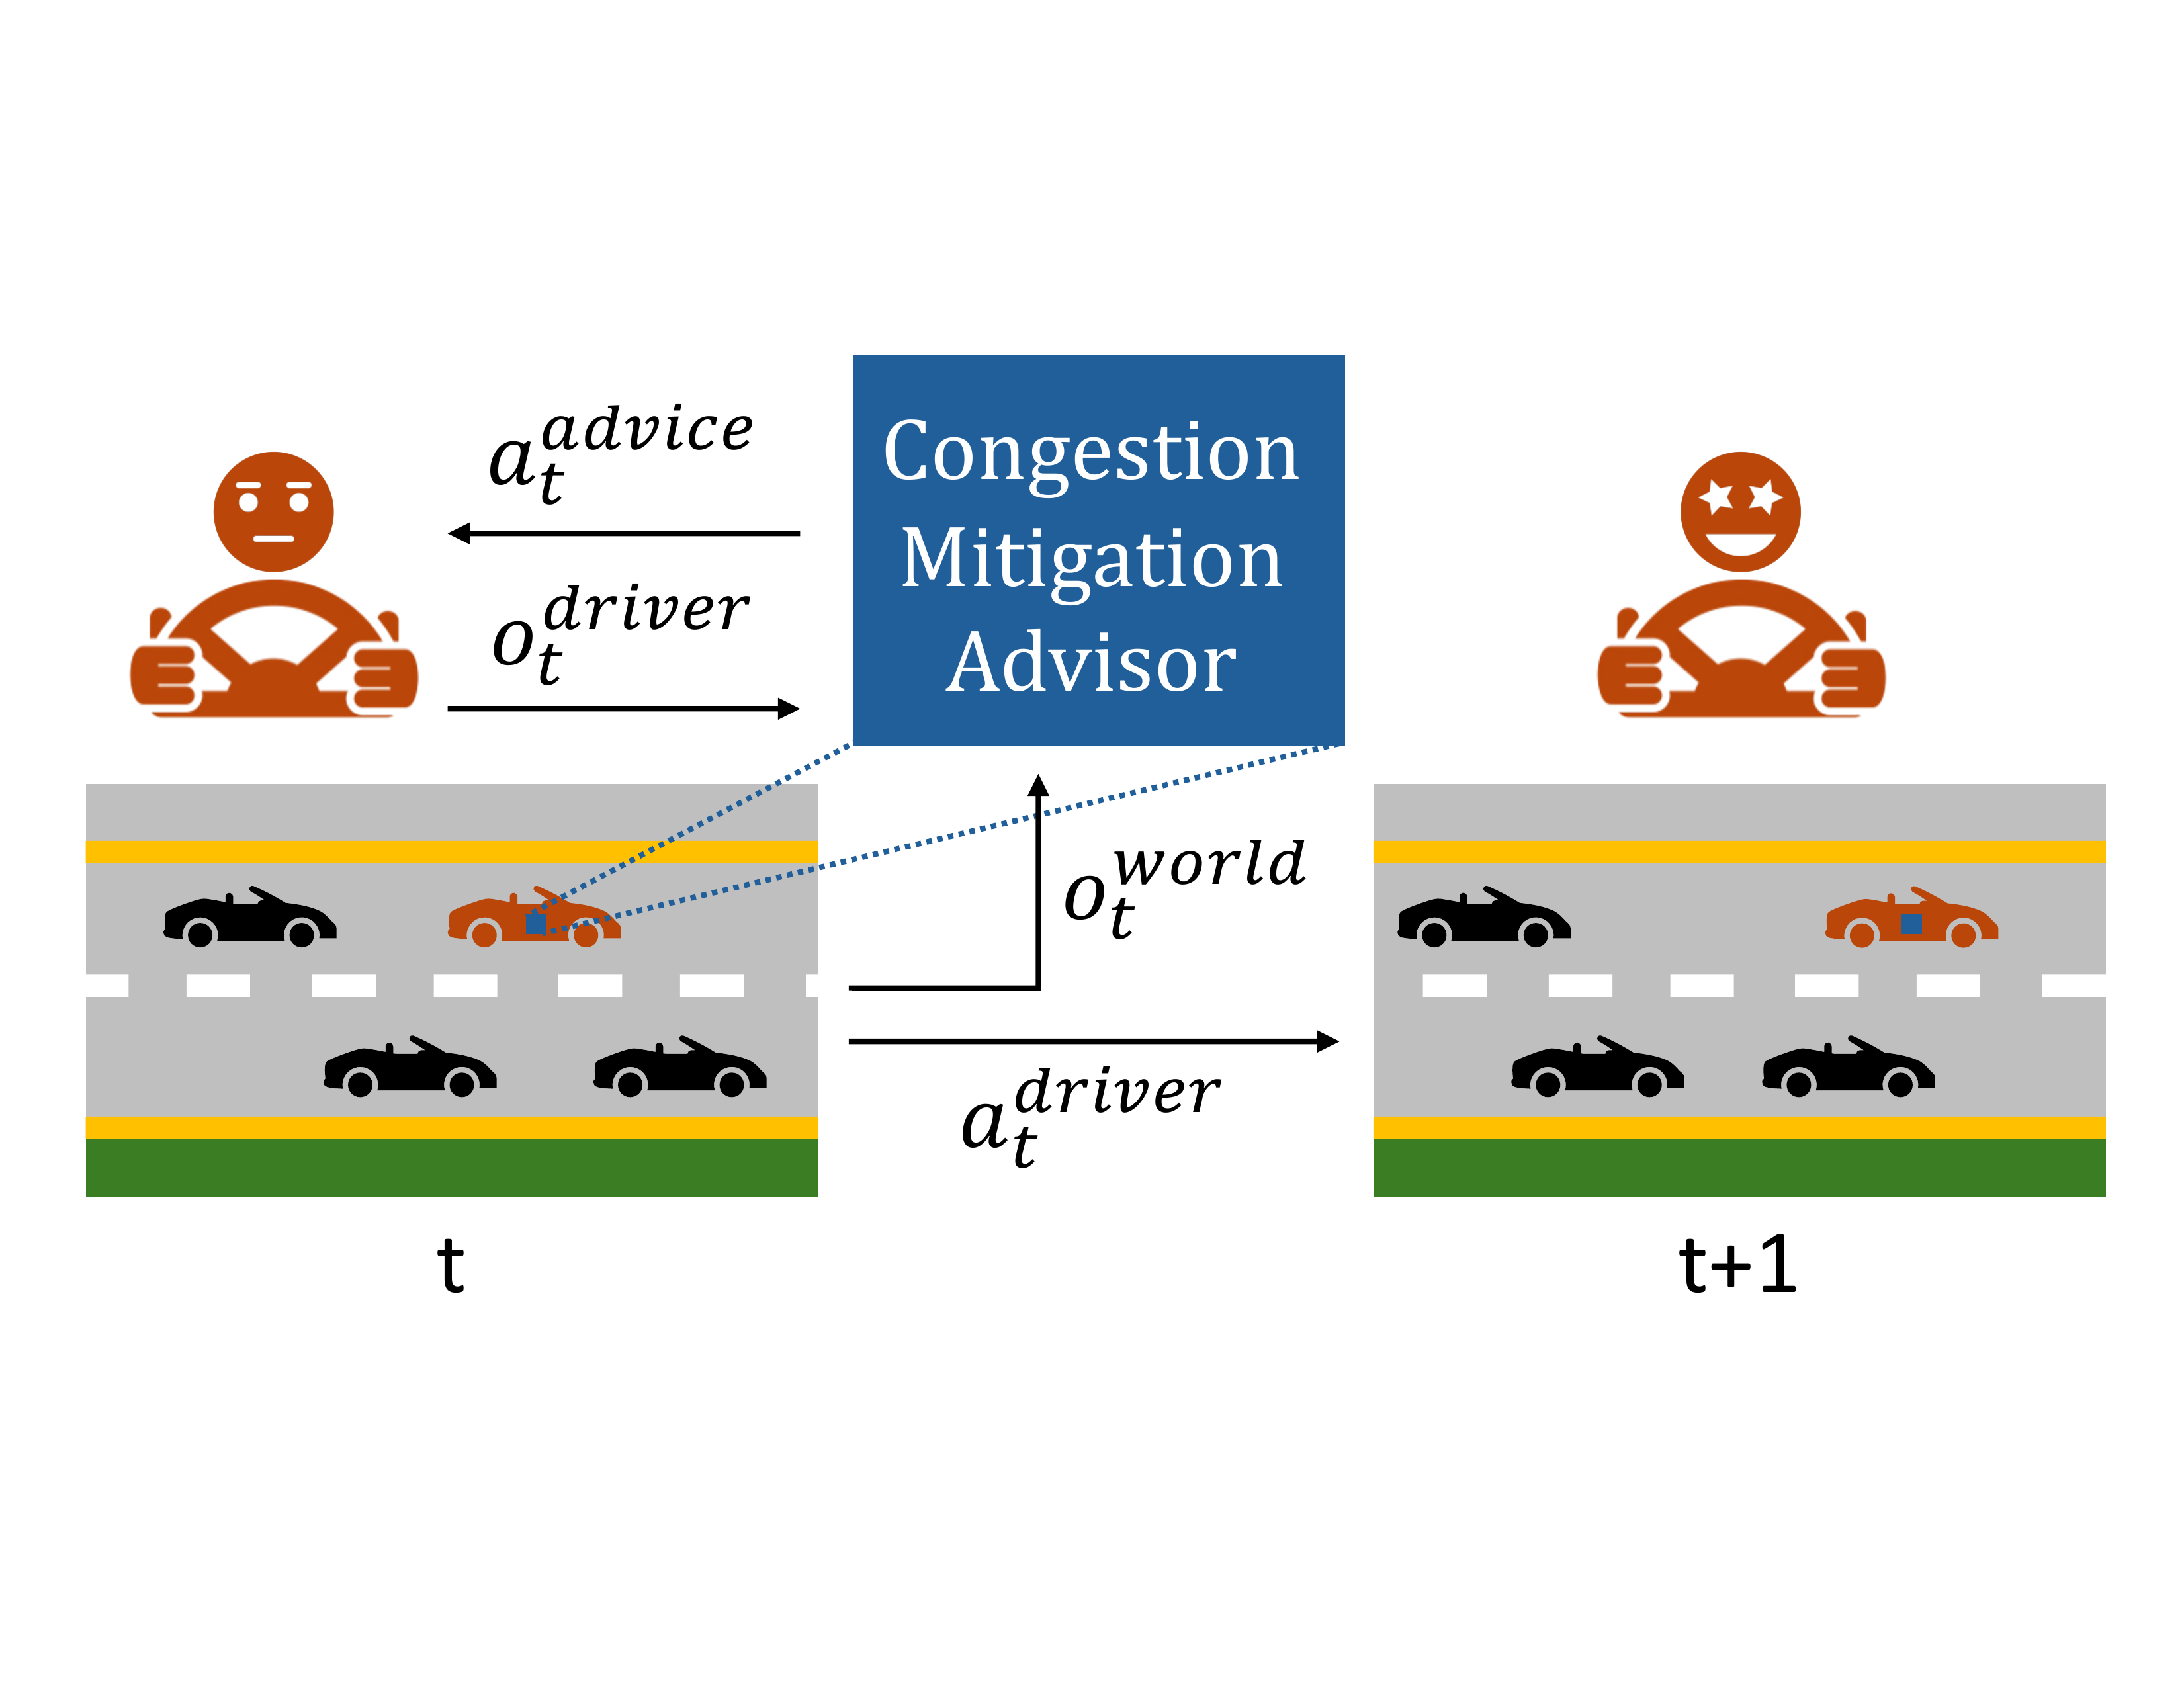
Cooperative Advisory Residual Policies for Congestion Mitigation Aamir Hasan,
Neeloy Chakraborty,
Haonan Chen,
Jung-Hoon Cho,
Cathy Wu,
Katherine Driggs-Campbell 2024 ACM Journal on Autonomous Transportation Systems, [Paper][BibTeX]@article{hasan2024cooperative,
title={{Cooperative Advisory Residual Policies for Congestion Mitigation}},
author={Hasan, Aamir and Chakraborty, Neeloy and Chen, Haonan and Cho, Jung-Hoon and Wu, Cathy and Driggs-Campbell, Katherine},
journal={ACM Journal on Autonomous Transportation Systems},
year={2024},
volume={2},
number={2},
pages={1--31},
doi={10.1145/3699519},
url={https://doi.org/10.1145/3699519}
}
Lessons in Cooperation: Driver Sentiments Toward Real-Time Advisory Systems Aamir Hasan,
Neeloy Chakraborty,
Haonan Chen,
Cathy Wu,
Katherine Driggs-Campbell 2025 IEEE Intelligent Transportation Systems Magazine, [Paper][BibTeX]@article{hasan2025lessons,
title={{Lessons in Cooperation: Driver Sentiments Toward Real-Time Advisory Systems}},
author={Hasan, Aamir and Chakraborty, Neeloy and Chen, Haonan and Wu, Cathy and Driggs-Campbell, Katherine},
journal={IEEE Intelligent Transportation Systems Magazine},
year={2025},
volume={17},
number={5},
pages={61--71},
doi={10.1109/mits.2025.3555564},
url={https://doi.org/10.1109/mits.2025.3555564}
}
Predicting Object Interactions with Behavior Primitives: An Application in Stowing Tasks Haonan Chen,
Yilong Niu*,
Kaiwen Hong*,
Shuijing Liu,
Yixuan Wang,
Yunzhu Li,
Katherine Driggs-Campbell * Equal contribution 2023 Conference on Robot Learning, [Project][Paper][BibTeX]@inproceedings{chen2023predicting,
title={{Predicting Object Interactions with Behavior Primitives: An Application in Stowing Tasks}},
author={Chen, Haonan and Niu, Yilong and Hong, Kaiwen and Liu, Shuijing and Wang, Yixuan and Li, Yunzhu and Driggs-Campbell, Katherine Rose},
booktitle={Proceedings of The 7th Conference on Robot Learning},
pages={358--373},
year={2023},
editor={Tan, Jie and Toussaint, Marc and Darvish, Kourosh},
volume={229},
series={Proceedings of Machine Learning Research},
month={06--09 Nov},
publisher={PMLR},
pdf={https://proceedings.mlr.press/v229/chen23a/chen23a.pdf},
url={https://proceedings.mlr.press/v229/chen23a.html}
} Finalist - Best Paper/Best Student Paper Awards
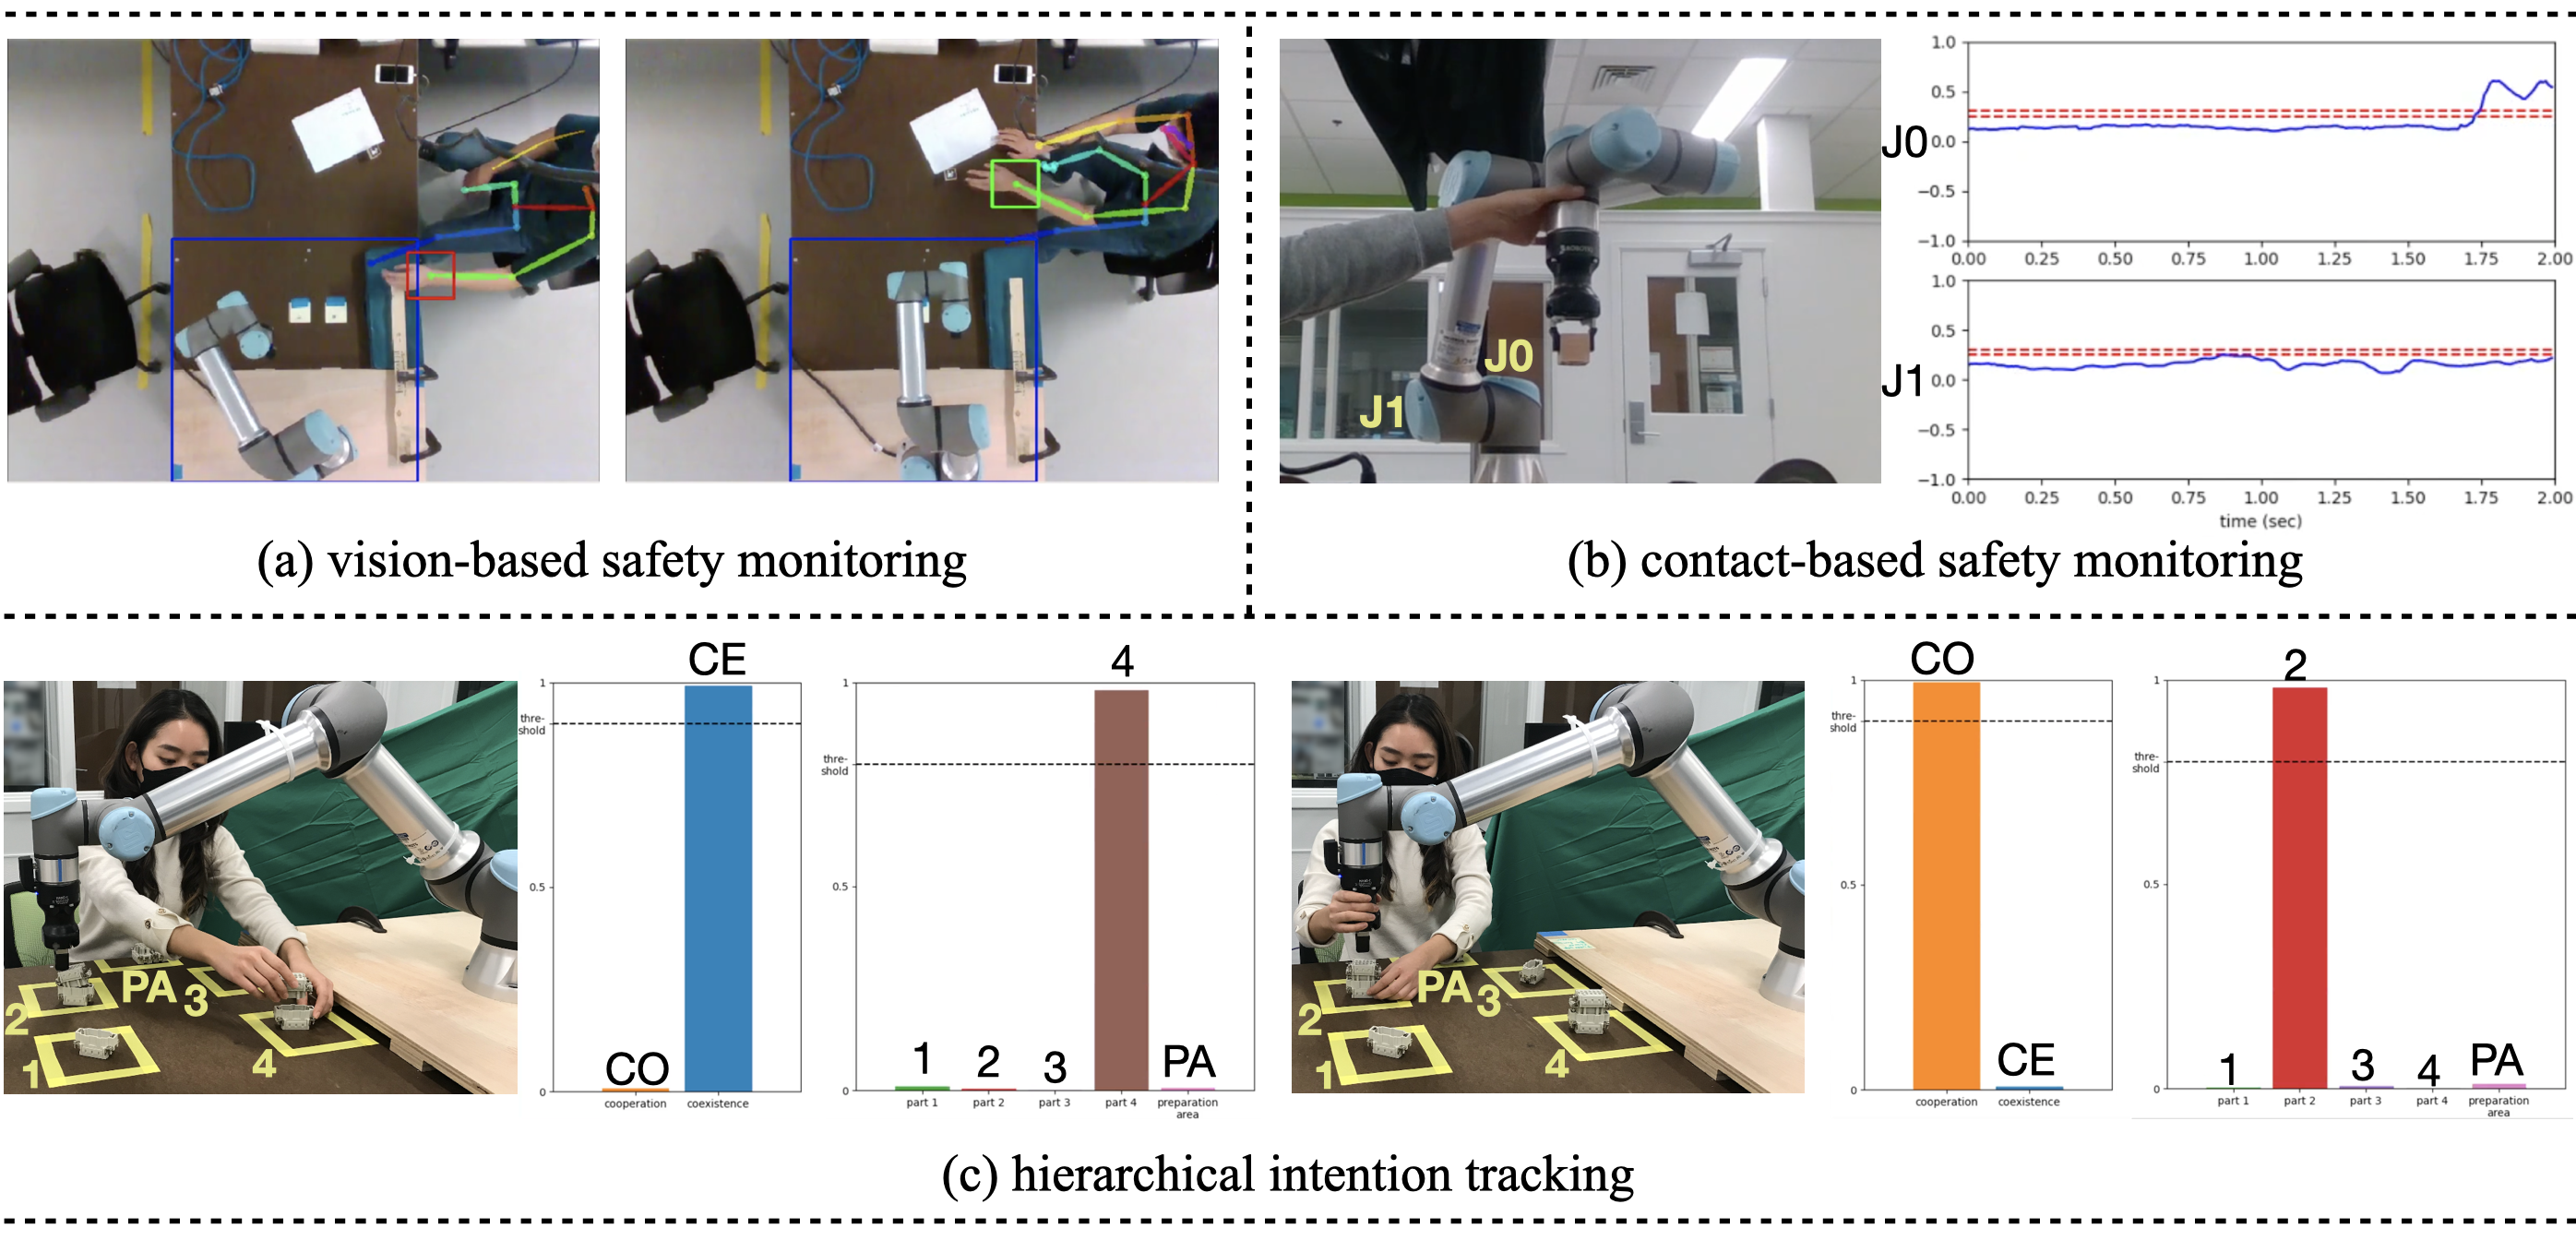
Towards Safe Multi-Level Human-Robot Interaction in Industrial Tasks Zhe Huang,
Ye-Ji Mun,
Haonan Chen,
Yiqing Xie,
Yilong Niu,
Xiang Li,
Ninghan Zhong,
Haoyuan You,
D. Livingston McPherson,
Katherine Driggs-Campbell 2023 IEEE International Conference on Automation Science and Engineering (Special Session), [Paper][BibTeX]@inproceedings{huang2023towards,
title={{Towards Safe Multi-Level Human-Robot Interaction in Industrial Tasks}},
author={Zhe Huang and Ye-Ji Mun and Haonan Chen and Yiqing Xie and Yilong Niu and Xiang Li and Ninghan Zhong and Haoyuan You and D. Livingston McPherson and Katherine Driggs-Campbell},
booktitle={IEEE International Conference on Automation Science and Engineering},
year={2023},
url={https://arxiv.org/abs/2308.03222}
}
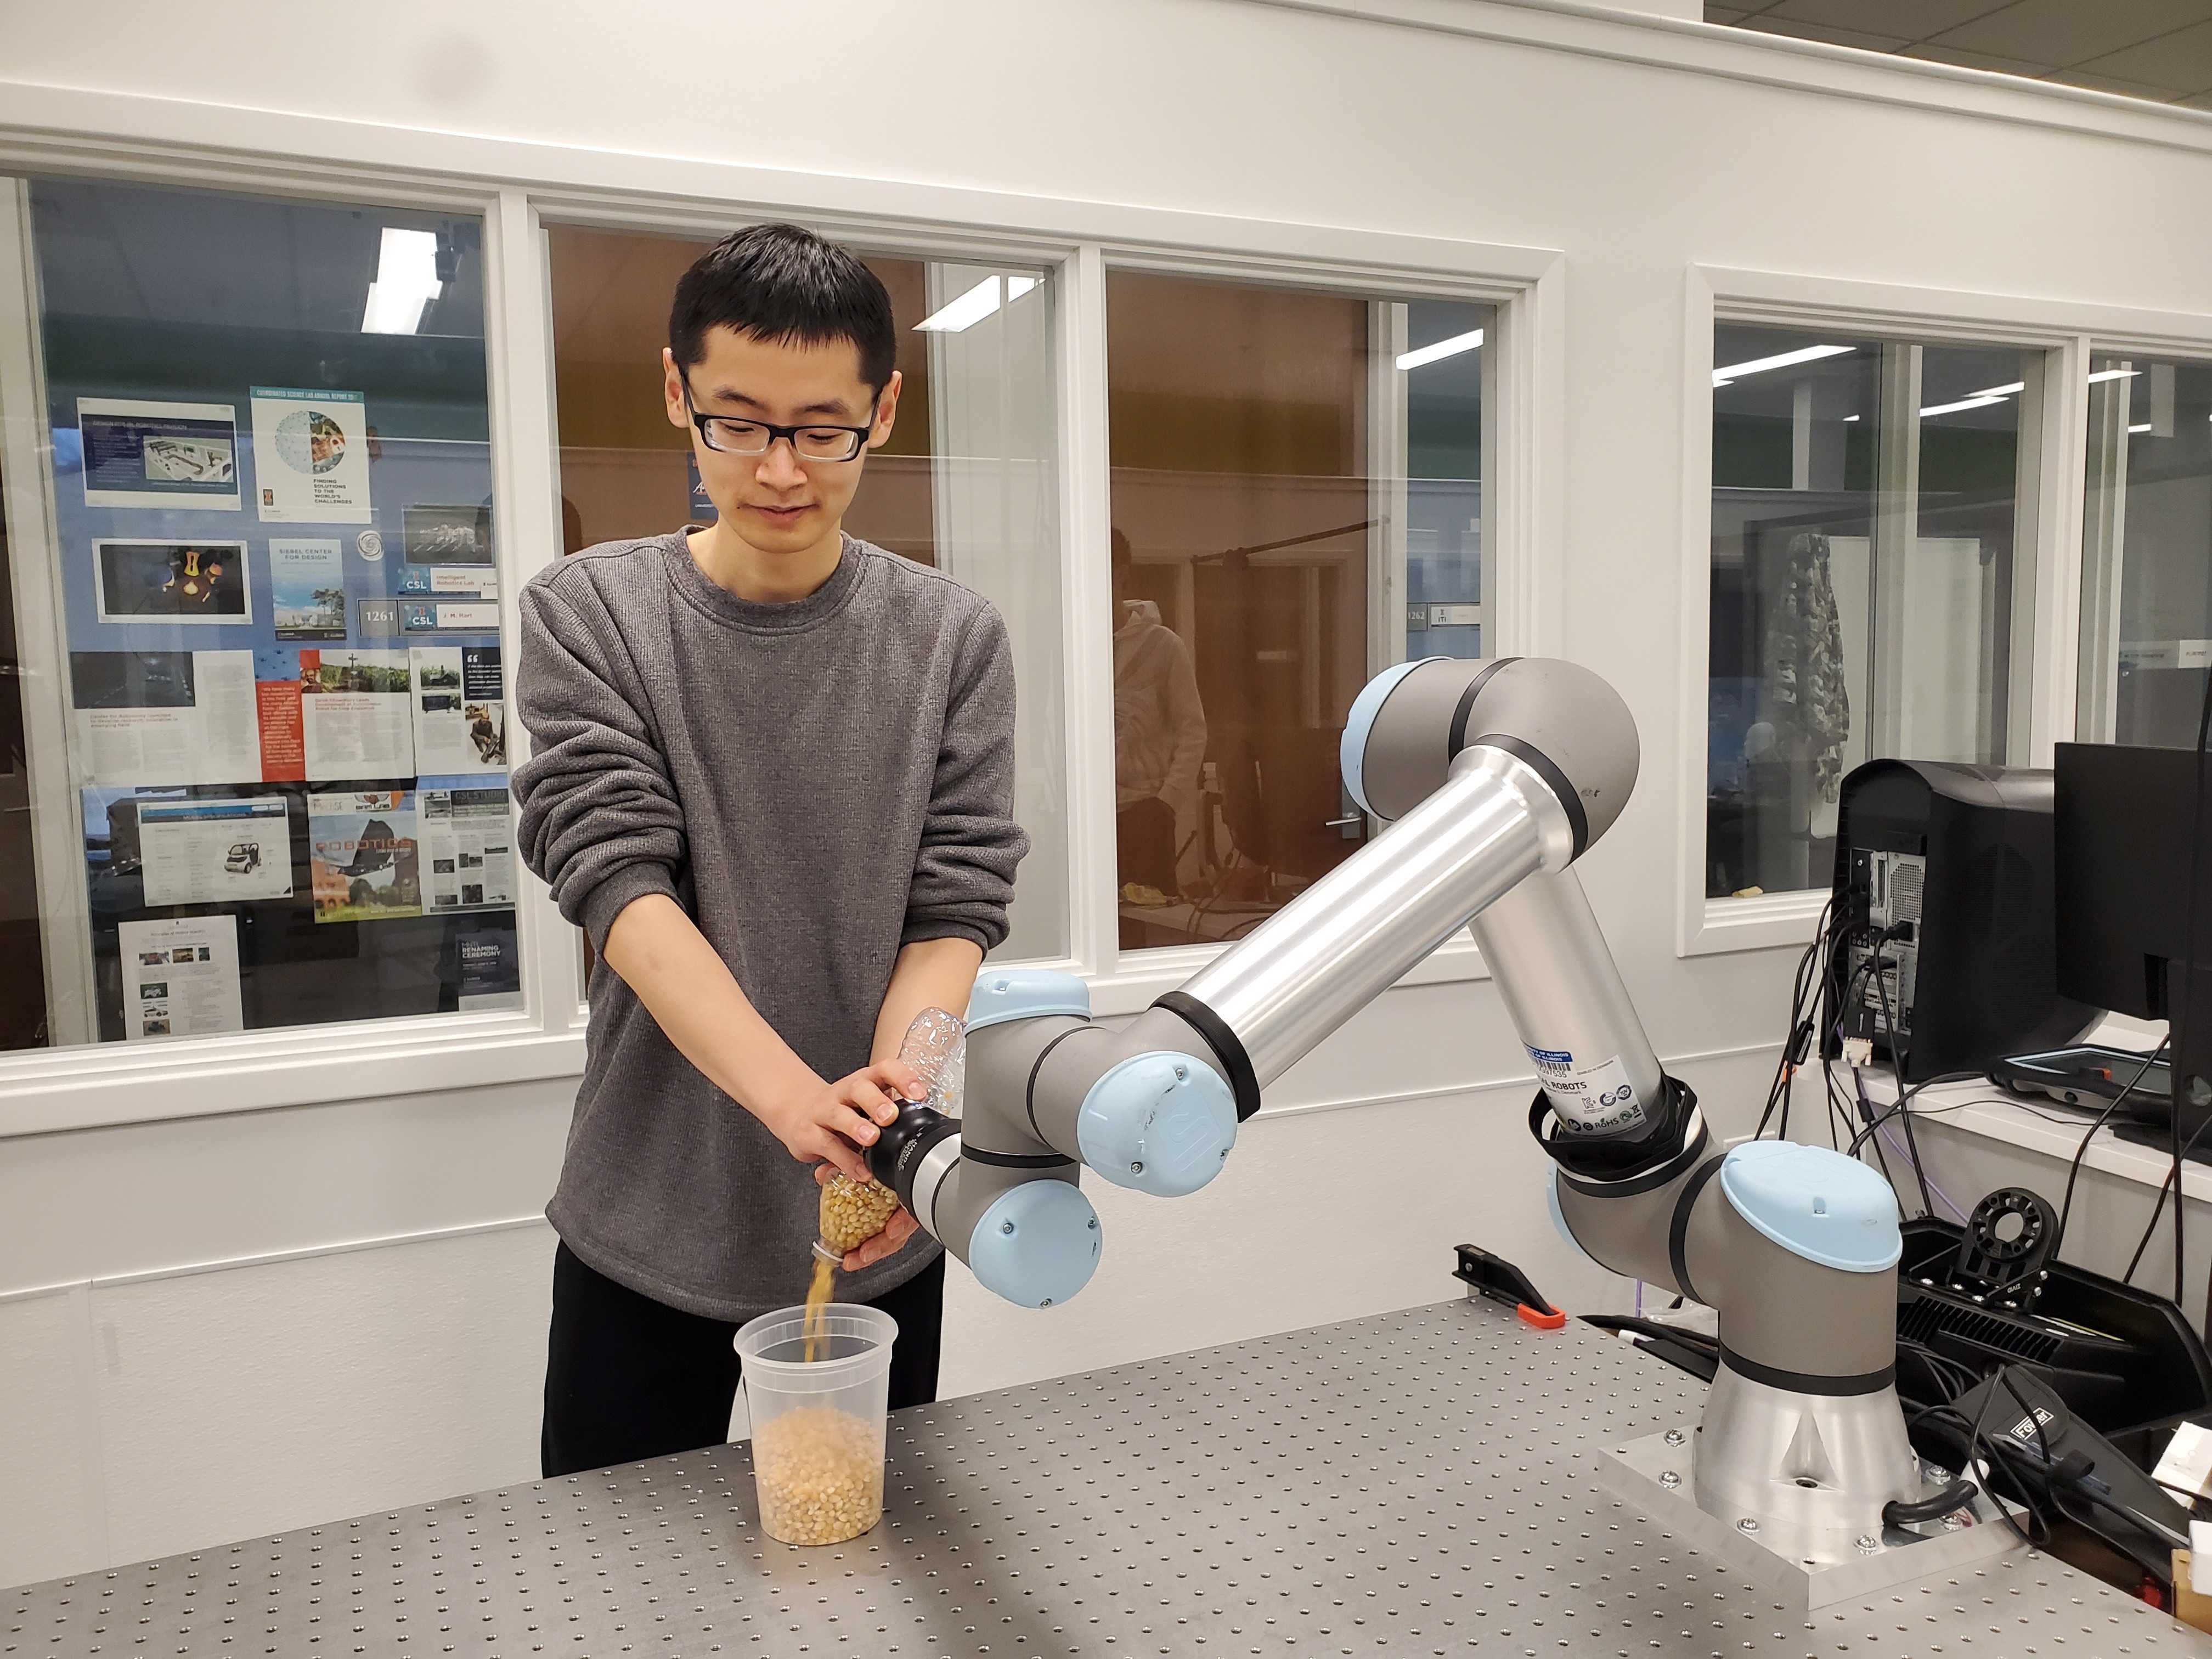
Learning Task Skills and Goals Simultaneously from Physical Interaction Haonan Chen*,
Ye-Ji Mun*,
Zhe Huang,
Yilong Niu,
Yiqing Xie,
D. Livingston McPherson,
Katherine Driggs-Campbell * Equal contribution 2023 IEEE International Conference on Automation Science and Engineering (Special Session), [Paper][BibTeX]@inproceedings{chen2023learning,
title={{Learning Task Skills and Goals Simultaneously from Physical Interaction}},
author={Haonan Chen and Ye-Ji Mun and Zhe Huang and Yilong Niu and Yiqing Xie and D. Livingston McPherson and Katherine Driggs-Campbell},
booktitle={IEEE International Conference on Automation Science and Engineering},
year={2023},
url={https://arxiv.org/abs/2309.04596}
}
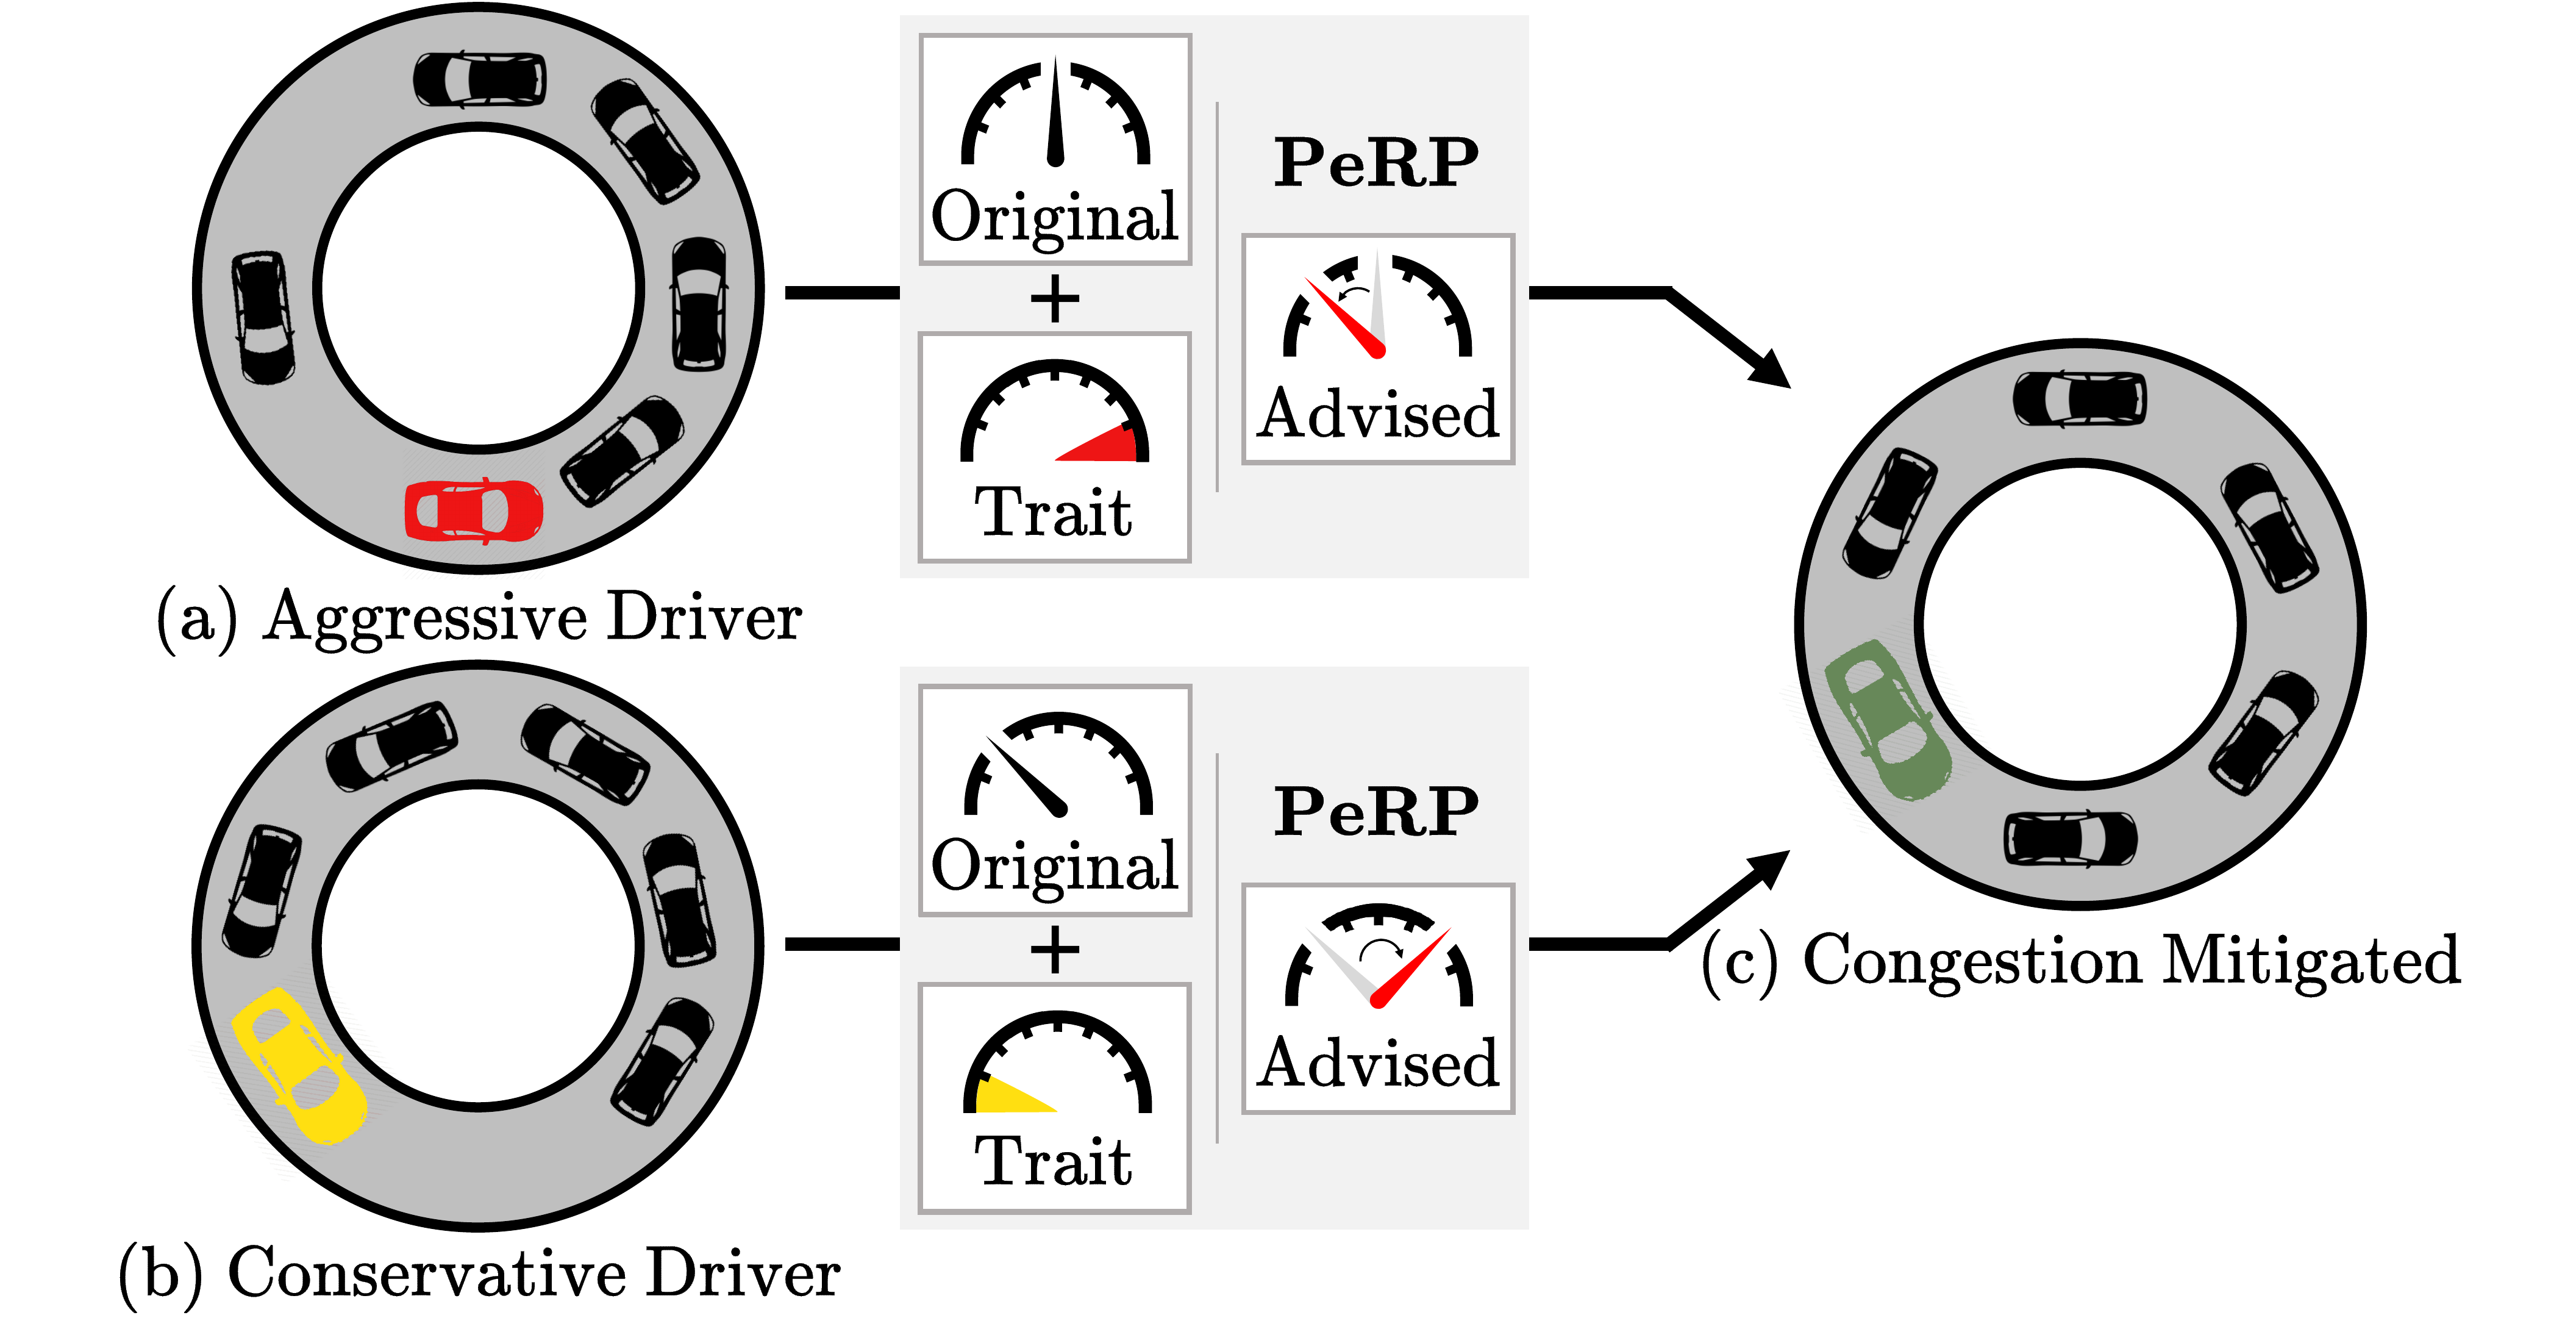
PeRP: Personalized Residual Policies For Congestion Mitigation Through Co-operative Advisory Systems Aamir Hasan,
Neeloy Chakraborty*,
Haonan Chen*,
Jung-Hoon Cho,
Cathy Wu,
Katherine Driggs-Campbell * Equal contribution 2023 IEEE International Conference on Intelligent Transportation Systems, [Paper][Website][BibTeX]@inproceedings{hasan2023perp,
title={{PeRP: Personalized Residual Policies For Congestion Mitigation Through Co-operative Advisory Systems}},
author={Hasan, Aamir and Chakraborty, Neeloy and Chen, Haonan and Cho, Jung-Hoon and Wu, Cathy and Driggs-Campbell, Katherine},
booktitle={2023 IEEE 26th International Conference on Intelligent Transportation Systems (ITSC)},
year={2023},
pages={5078--5085},
doi={10.1109/itsc57777.2023.10422444},
url={https://doi.org/10.1109/itsc57777.2023.10422444}
}
Combining Model-Based Controllers and Generative Adversarial Imitation Learning for Traffic Simulation Haonan Chen,
Tianchen Ji,
Shuijing Liu,
Katherine Driggs-Campbell 2022 IEEE International Conference on Intelligent Transportation Systems, [Paper][BibTeX]@inproceedings{chen2022combining,
title={{Combining Model-Based Controllers and Generative Adversarial Imitation Learning for Traffic Simulation}},
author={Chen, Haonan and Ji, Tianchen and Liu, Shuijing and Driggs-Campbell, Katherine},
booktitle={2022 IEEE 25th International Conference on Intelligent Transportation Systems (ITSC)},
year={2022},
pages={1698--1704},
doi={10.1109/itsc55140.2022.9922261},
url={https://doi.org/10.1109/itsc55140.2022.9922261}
}
Learning to Navigate Intersections with Unsupervised Driver Trait Inference Shuijing Liu,
Peixin Chang,
Haonan Chen,
Neeloy Chakraborty,
Katherine Driggs-Campbell 2022 IEEE International Conference on Robotics and Automation, [Paper][Website][Video][BibTeX]@inproceedings{liu2022learning,
title={{Learning to Navigate Intersections with Unsupervised Driver Trait Inference}},
author={Liu, Shuijing and Chang, Peixin and Chen, Haonan and Chakraborty, Neeloy and Driggs-Campbell, Katherine},
booktitle={2022 International Conference on Robotics and Automation (ICRA)},
year={2022},
pages={3576--3582},
doi={10.1109/icra46639.2022.9811635},
url={https://doi.org/10.1109/icra46639.2022.9811635}
}
Robot Sound Interpretation: Combining Sight and Sound in Learning-Based Control Peixin Chang,
Shuijing Liu,
Haonan Chen,
Katherine Driggs-Campbell 2020 IEEE/RSJ International Conference on Intelligent Robots and Systems, [Paper][Video][BibTeX]@inproceedings{chang2020robot,
title={{Robot Sound Interpretation: Combining Sight and Sound in Learning-Based Control}},
author={Chang, Peixin and Liu, Shuijing and Chen, Haonan and Driggs-Campbell, Katherine},
booktitle={2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
year={2020},
pages={5580--5587},
doi={10.1109/iros45743.2020.9341196},
url={https://doi.org/10.1109/iros45743.2020.9341196}
}
Awards and Honors
Outstanding Reviewer, Conference on Robot Learning (CoRL) 2026
Finalist - Best/Outstanding Paper Awards, Robotics: Science and Systems 2026
Conference Travel Award, Graduate College, University of Illinois Urbana-Champaign 2023
Finalist - Best Paper/Best Student Paper Awards, Conference on Robot Learning 2023
Bronze Tablet Award, University of Illinois Urbana-Champaign 2020
Excellent Graduate, Zhejiang University 2020
Student Speaker at Graduation, ZJU-UIUC Institute 2020
Provincial Scholarship, Zhejiang Province, China (Top 3%) 2019
Dean's List, University of Illinois Urbana-Champaign 2019
National Scholarship, China (Top 1.8%) 2018
Excellent Undergraduate Scholarship, Zhejiang University (Top 3%) 2018-2019
Academic Excellence Scholarship Award, ZJU-UIUC Institute 2017-2019
Top Ten Social Practice, Zhejiang University (Top 1.5%) 2017